Space Station Robotic Arm
Aerospace · Interactive
- DimensionsSubject to on-site plan
- PresentationInteractive
- PricingQuoted by manufacture spec
Purpose & Scientific Principle
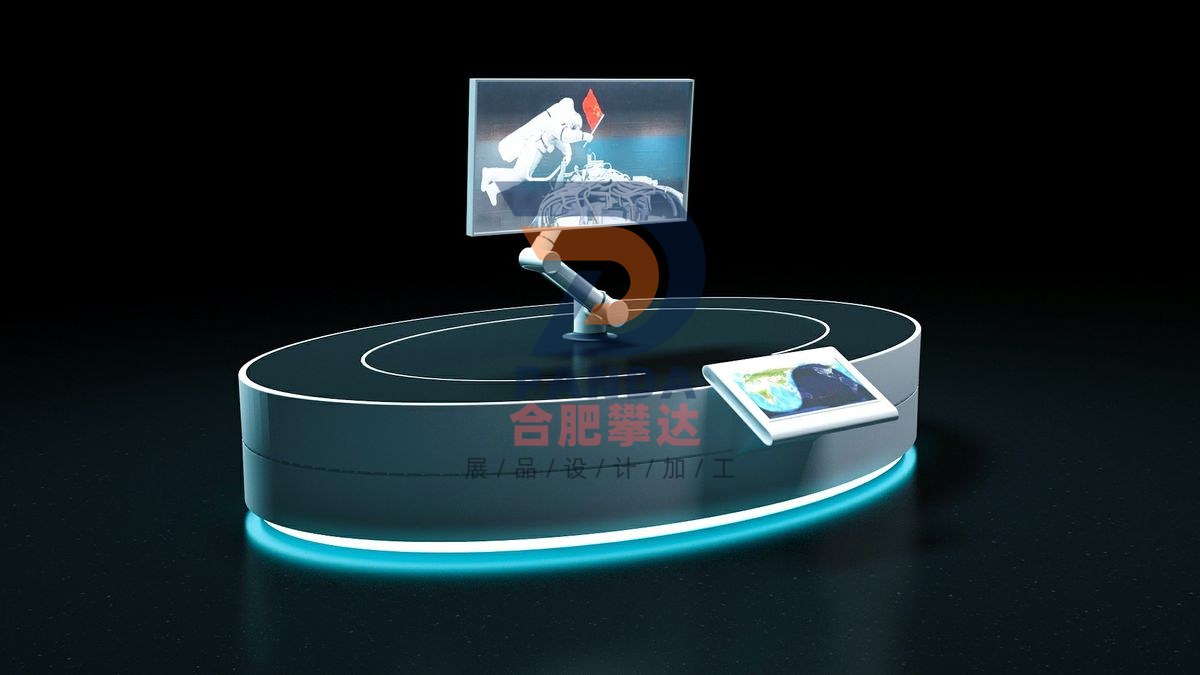
The exhibits showcase the appearance of China's independently developed space station robotic arm and its on-orbit operation through the display of robotic arm maneuvering models and multimedia interaction, leading the audience to explore the technical application of space robotic arms and witness the capabilities and level of China's space station in orbit construction.
How to Operate
The core module robotic arm of the space station is my country's first robotic arm that can operate in space orbit for a long time. It is composed of the core module robotic arm (big arm) and the "Wentian" experimental module robotic arm (small arm). The big arm is about 10.2 meters, with a maximum load-bearing capacity of 25 tons; the small arm is about 5 meters, with a maximum load-bearing capacity of 3 tons. Large and small robotic arms can complete tasks individually or can be combined into a combined robotic arm of about 15 meters to complete tasks such as cabin translocation, hover capture, cargo handling, equipment installation, astronaut exit, extravehicular status inspection, load care, platform maintenance and other tasks. The robotic arm has three joints on the shoulder, one joint on the elbow, and three joints on the wrist. Each joint corresponds to a degree of freedom. Through the rotation of each joint, it can grasp and operate at any angle from front to back, left, and right. An end effector is installed on each shoulder and wrist of the robotic arm. As the tentacles of the robotic arm, the end effector can be docked with a target adapter installed on the surface of the cabin. Through the docking and separation of the end effector and the target adapter, it cooperates with the joint motion of each joint to achieve crawling transfer on the cabin.
The exhibits focus on displaying the space robotic arm and the implementation of its main tasks. Based on the functions and characteristics of the first set of space station core module robotic arms independently developed by my country, a set of collaborative robotic arms is set up on the table, with a linked display at the end. Through electromechanical and software control, and controlled by the table touch screen, the robotic arm moves slowly according to a predetermined trajectory, truly restoring and interpreting the scene of the robotic arm operating in orbit, presenting an interactive effect that combines reality and reality.
Related Exhibits
Need a quote for this piece or a full exhibit configuration? Tell us your venue area, theme direction, and budget range.